Singularity-Free Guiding Vector Fields on SO(3) with Designer-Specified Progression Behavior
J. Bautista, HG de Marina
Submitted to Automatica · 2026
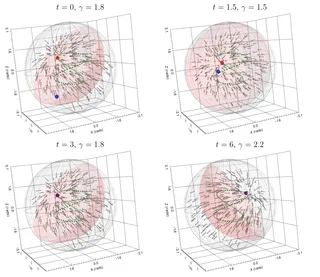
This paper develops a singularity-free guiding vector field (SF-GVF) for path following on the special orthogonal group SO(3). First, we lift the Euclidean SF-GVF construction to SO(3), integrating the augmented-state approach with the intrinsic Lie-group geometry and obtaining a closed-form geometric guidance law whose integral curves converge to a designer-specified attitude path. The field is defined on a dense open subset of SO(3), excluding only the measure-zero antipodal set — a manifestation of the topological obstruction to continuous global stabilization on SO(3). The construction requires no per-step optimization and produces a control input intrinsically in mathfrakso(3) as body angular rates. Second, we formalize the progression behavior along the path as a designer-supplied function nu(xi), promoting the parametric speed from an implicitly resolved degree of freedom to a first-class design specification. In contrast to the Euclidean condition v = 0, which excludes vehicles with minimum-speed constraints, the corresponding condition omega = 0 on SO(3) is physically admissible for most platforms with active attitude control, making the progression behavior a design freedom structurally available on SO(3) but absent in the Euclidean setting. The framework's structural results are established under a bi-invariant Riemannian metric and hold uniformly across choices of path, progression, and Lyapunov gain. The framework is illustrated in simulation on self-intersecting paths under both constant and point-convergence progression behaviors.