Research
My work spans these topics. Each one lists the papers and videos that belong to it.
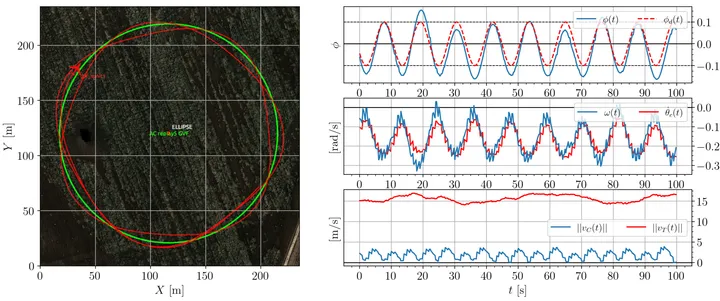
Guiding vector fields
Path following on Euclidean spaces and manifolds, with control over how the robot converges and moves along the path.
4 papers · 4 videos
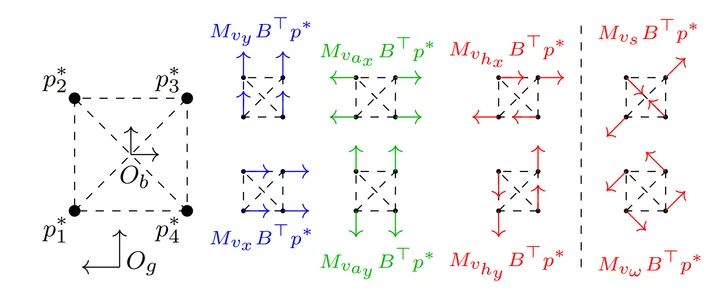
Formation control
Distributed coordination of robot swarms: collective motions, circular formations and dispersion shapes.
4 papers · 2 videos
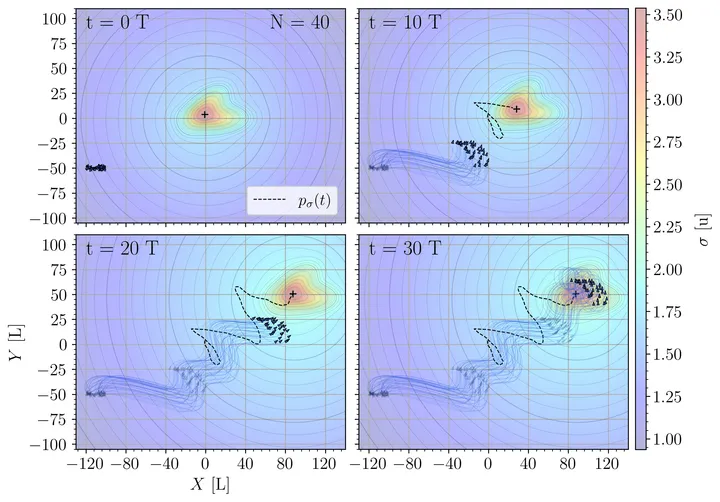
Source seeking
Robot swarms that find the source of an unknown scalar field - without gradient measurements and resilient to robot failures.
3 papers
Geometric control on SO(3)
Attitude control directly on the rotation group: no Euler-angle singularities, no quaternion ambiguities.
3 papers
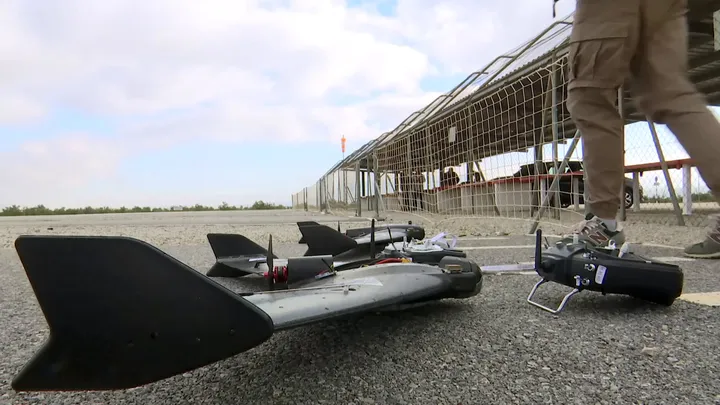
Autonomous fixed-wing aircraft
From theory to flight: formation flight, crosswind navigation and autonomous aerobatics on real drones.
2 papers · 5 videos